Sense
Environmental sensors, user input and optional wearables provide context about what is happening around the person.
A calm home robot designed around usefulness rather than spectacle: ambient assistance, reminders, telepresence, contextual AI and safe physical interaction.
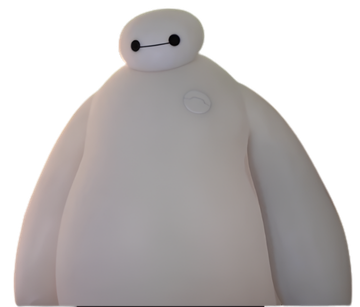
The useful part of a Baymax-like vision is not copying a movie character. It is designing a machine that combines a conversational assistant with real-world sensing and limited physical capability while remaining calm, transparent and easy for a person to control.
Environmental sensors, user input and optional wearables provide context about what is happening around the person.
An AI assistant identifies the user’s request, relevant context and whether the situation is routine or needs escalation.
The system provides reminders, guidance, telepresence or simple physical help within clearly defined capabilities.
For health or safety issues, the assistant connects the user to an appropriate human professional instead of pretending to replace one.
A safe mobile platform, expressive interaction, proximity sensing and simple manipulators could make the assistant useful in a home.
Speech, vision, language models and personalization could help the system interpret context and respond naturally.
Health-related features would require clinical validation, privacy controls and explicit escalation to qualified professionals.
Target electrical, mechanical and algorithmic thresholds derived from peer-reviewed BCI and robotics literature. All limits represent test criteria rather than commercial claims.
| ENGINEERING PARAMETER | TARGET THRESHOLD | PHYSICAL TOLERANCE / LIMIT | TEST RATIONALE |
|---|---|---|---|
| Pneumatics & Compliant Skin | Thermoplastic Polyurethane (TPU) + 0.8 PSI Low-Pressure Bladder | < 12 N maximum contact impact force | Soft inflatable outer shell ensures inherent passive safety when interacting physically with children or elderly occupants. |
| Spatial Perception & Obstacle Avoidance | Solid-State LiDAR (64-beam, 8m range) + Dual 120° Stereo Cameras | 2 cm depth accuracy @ 30 FPS | Provides real-time occupancy grid mapping while detecting non-planar obstacles, clear glass doors, and ground hazards. |
| Acoustic Processing & Wake-Word | 6-Microphone Circular Beamforming Array | SNR > 24 dB in 65 dBA ambient noise | On-device hardware acoustic echo cancellation (AEC) isolates speaker voice across household acoustic reverberations. |
| On-Device Edge AI Acceleration | 32 TOPS Low-Power Neural Processing Unit (NPU) | < 95 ms end-to-end intent response | Locally executes speech-to-text, visual feature extraction, and intent classification without sending raw household video to cloud servers. |
| Privacy Hardening & Data Flow | Hardware Optical Shutter + Local-Only Ephemeral Vector Store | Zero raw video/audio persistent storage | Physical disconnects for camera and microphone guarantee verifiable privacy compliance in domestic living spaces. |
A consumer robot should not present unvalidated AI output as a medical diagnosis. Early versions should focus on assistance, monitoring and connecting users with clinicians.
Cameras, microphones and health information create a major privacy burden. Local processing and transparent controls should be default design goals.
The interaction has to be predictable, respectful and easy to stop. A technically impressive robot that makes people uncomfortable has failed its product goal.
This concept is open to people interested in human-centered robotics: sensing, conversational AI, embedded systems, safe motion, interaction design and assistive interfaces. Collaboration should focus on a realistic function that can be prototyped and evaluated with people.
Tell us which interaction or hardware capability you want to prototype and how you would test whether it is genuinely useful.